Deterministic 3D Global Path Planning for Outdoor UGVs & AMRs.
Trail3D: Stop robots from tipping or stalling on uneven terrain.
Trail3D is a high-speed Rust pathfinding engine that enforces strict slope constraints over continuous elevation models—delivering physically viable, repeatable routes for autonomous vehicles in agriculture, mining, and construction.
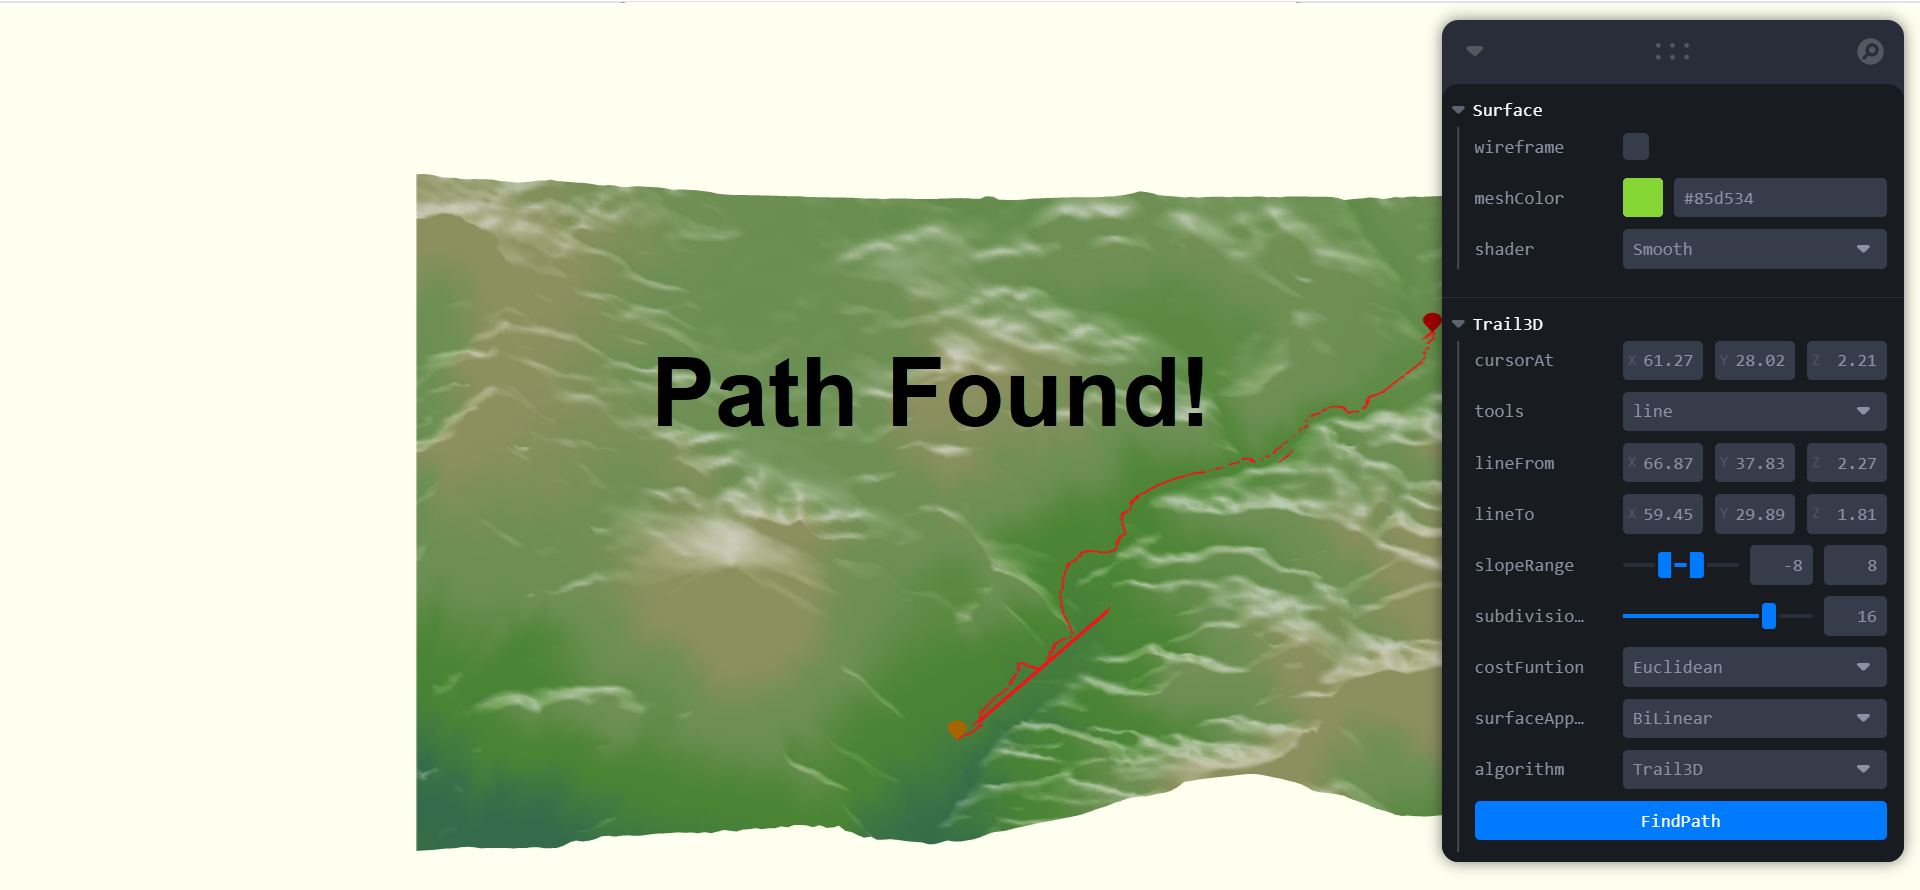
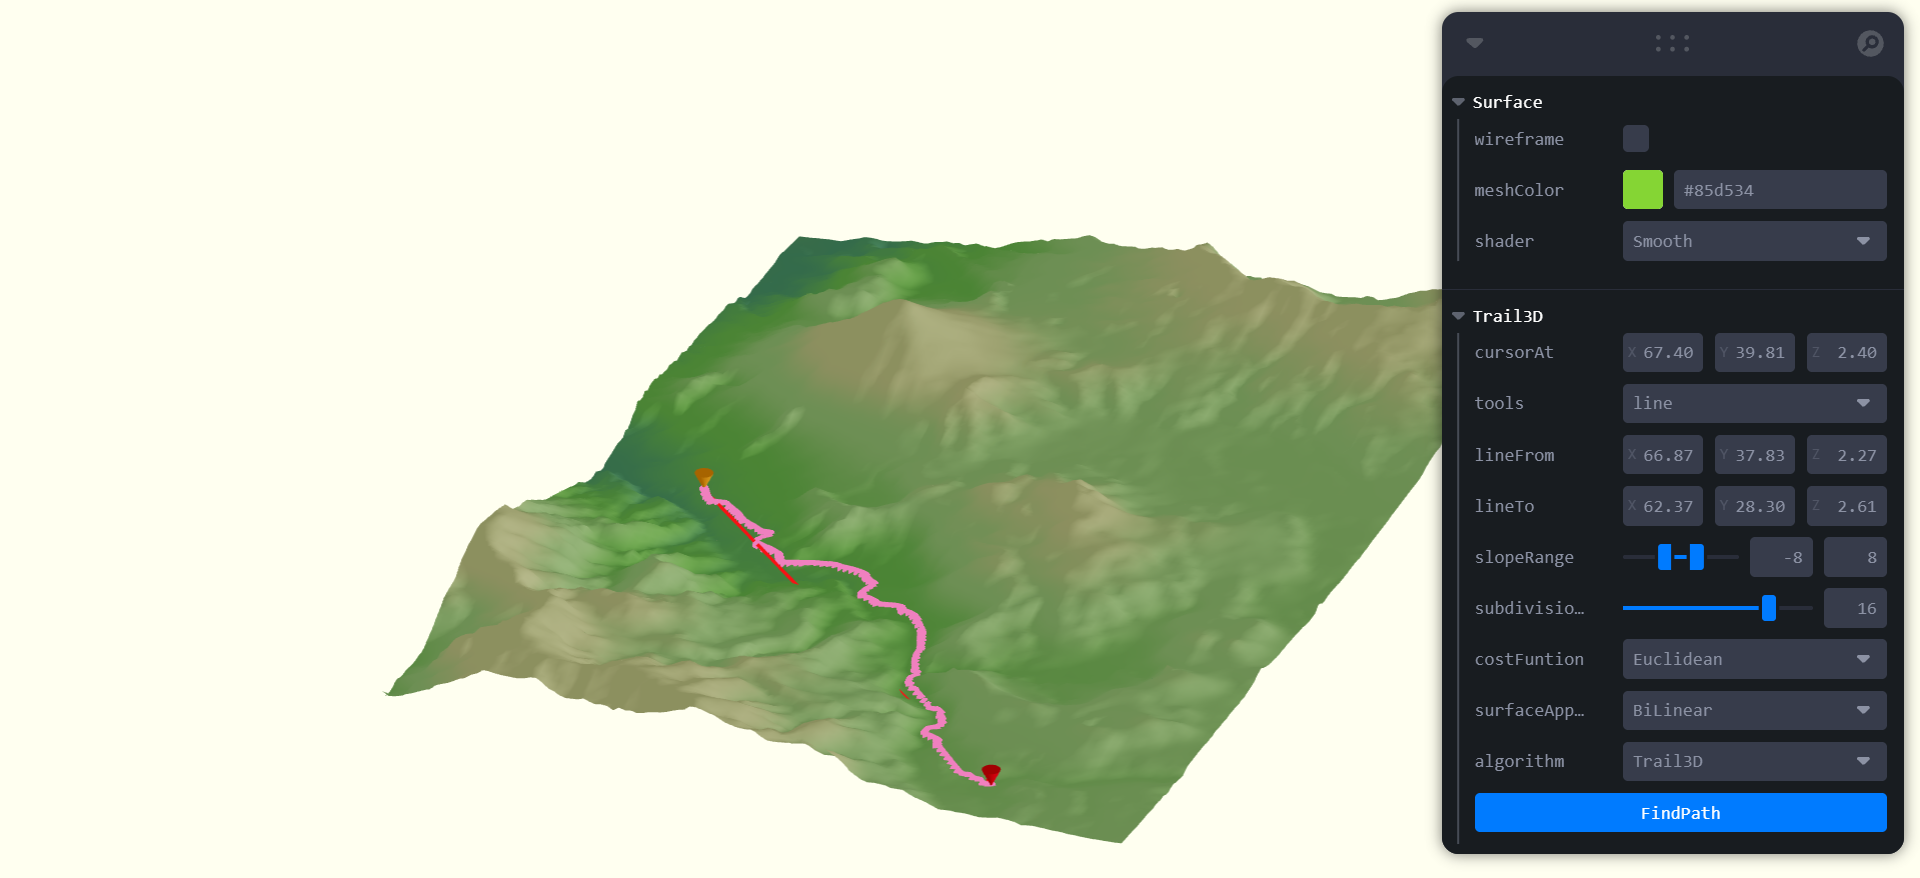
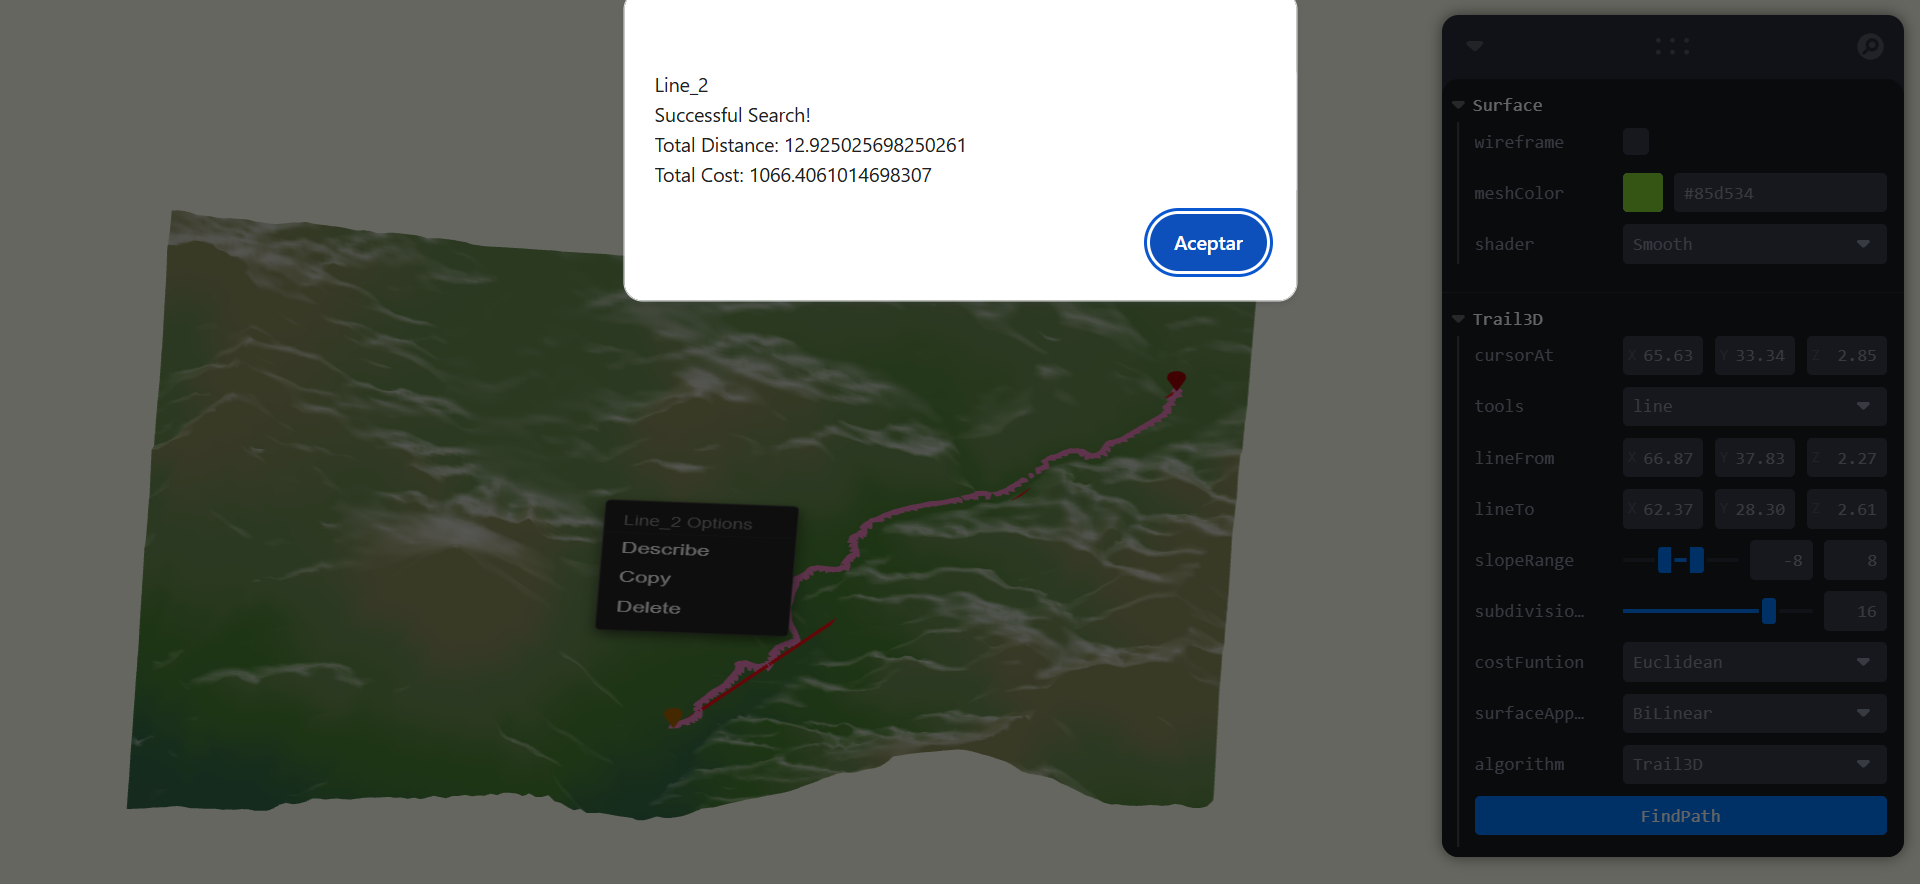
The Solution Provider
Reliable Surface Navigation Planning, Engineered by REDES 3D.
At REDES 3D, we develop advanced 3D software tools specifically designed to solve the most complex challenges in reliable surface navigation for industrial and autonomous applications.
Core Capabilities
Pathfinding with Real-World Constraints.
Continuous Surface Interpolation
Evaluates localized terrain gradients using Bilinear and Lagrange interpolation rather than coarse 2D grid approximations.
Hard Kinematic Slope Limits
Enforces strict minimum and maximum permissible grade angles so vehicles never exceed safe pitch and roll thresholds.
100% Deterministic Execution
Zero stochastic variance. Identical terrain inputs and constraints always produce the exact same verified trajectory.
Edge-Ready Rust Performance
Our goal, is to compile to native C/C++ shared libraries (.so/.dll) for real-time onboard compute device, alongside WebAssembly for browser simulation.
Get Started
Using Trail3D: A Step-by-Step Guide.
▶ The Demo Interface Explained
This quick guide covers the necessary steps to generate your first constrained, deterministic path. Remember that precise input parameters are key to reliable output.
Try it for free, no registration or credit card needed!
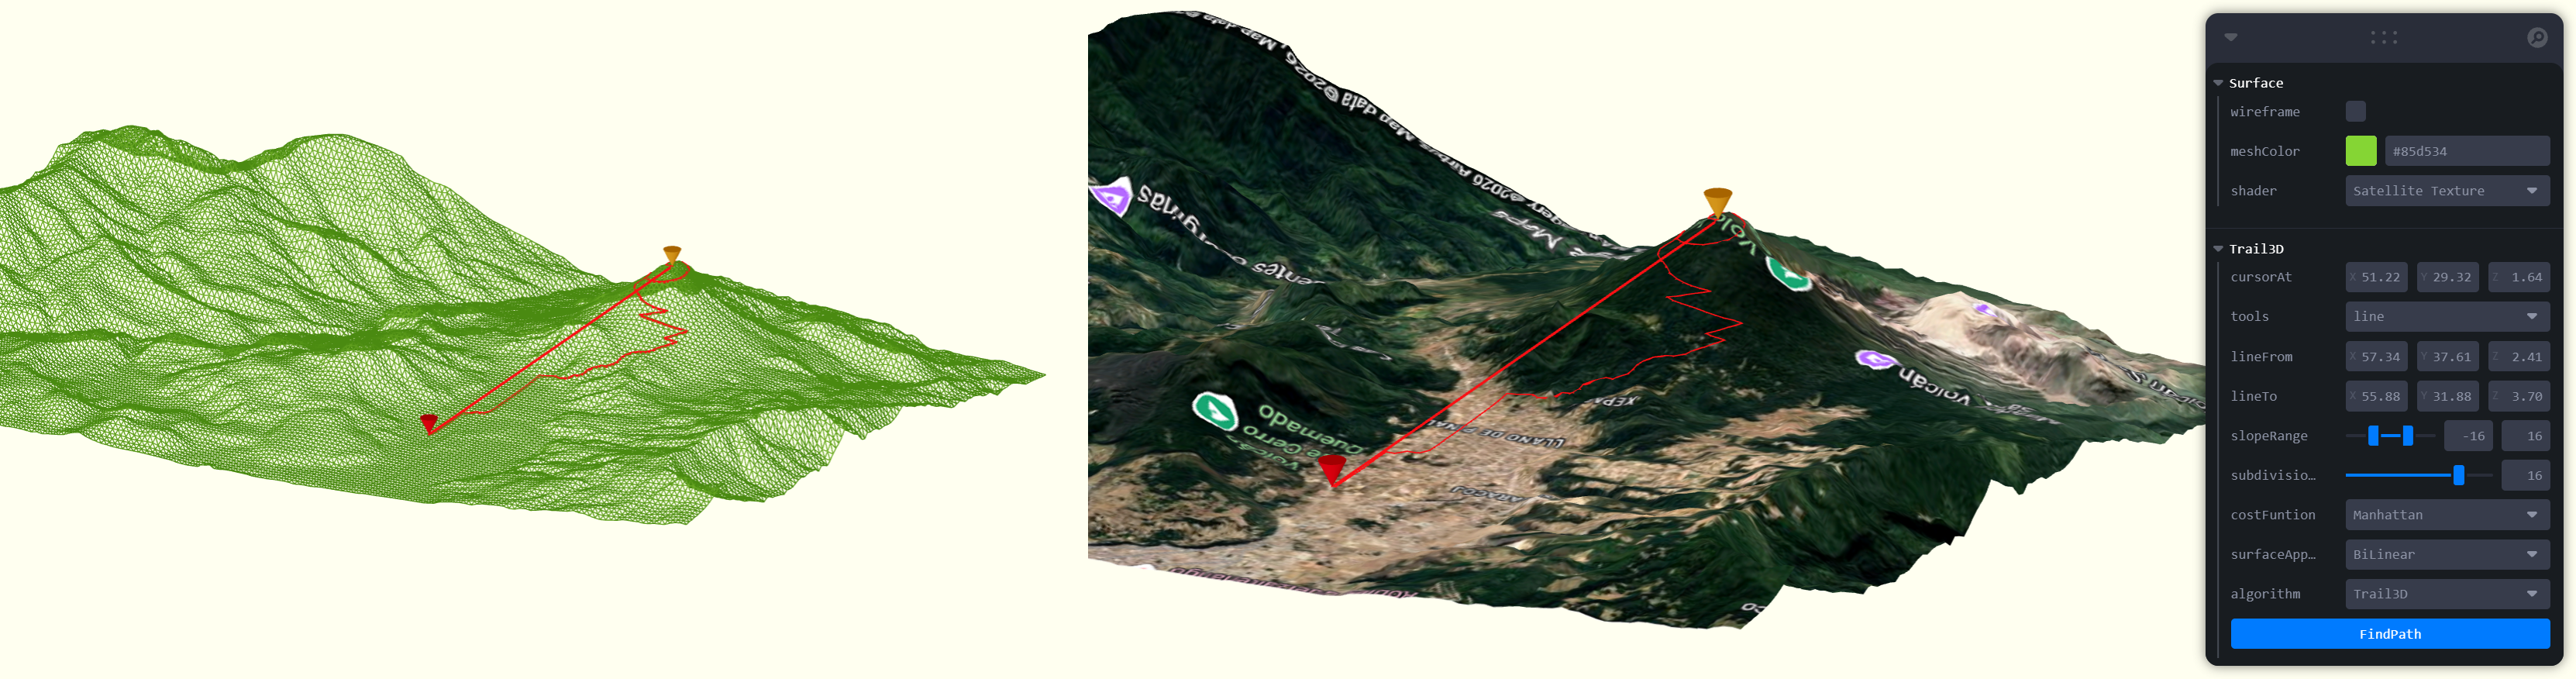
Demo with React Three Fiber (R3F) Recommend browser resolution: 1280 x 593 pixels
🚀 Quick Path Generation Guide
Set the View
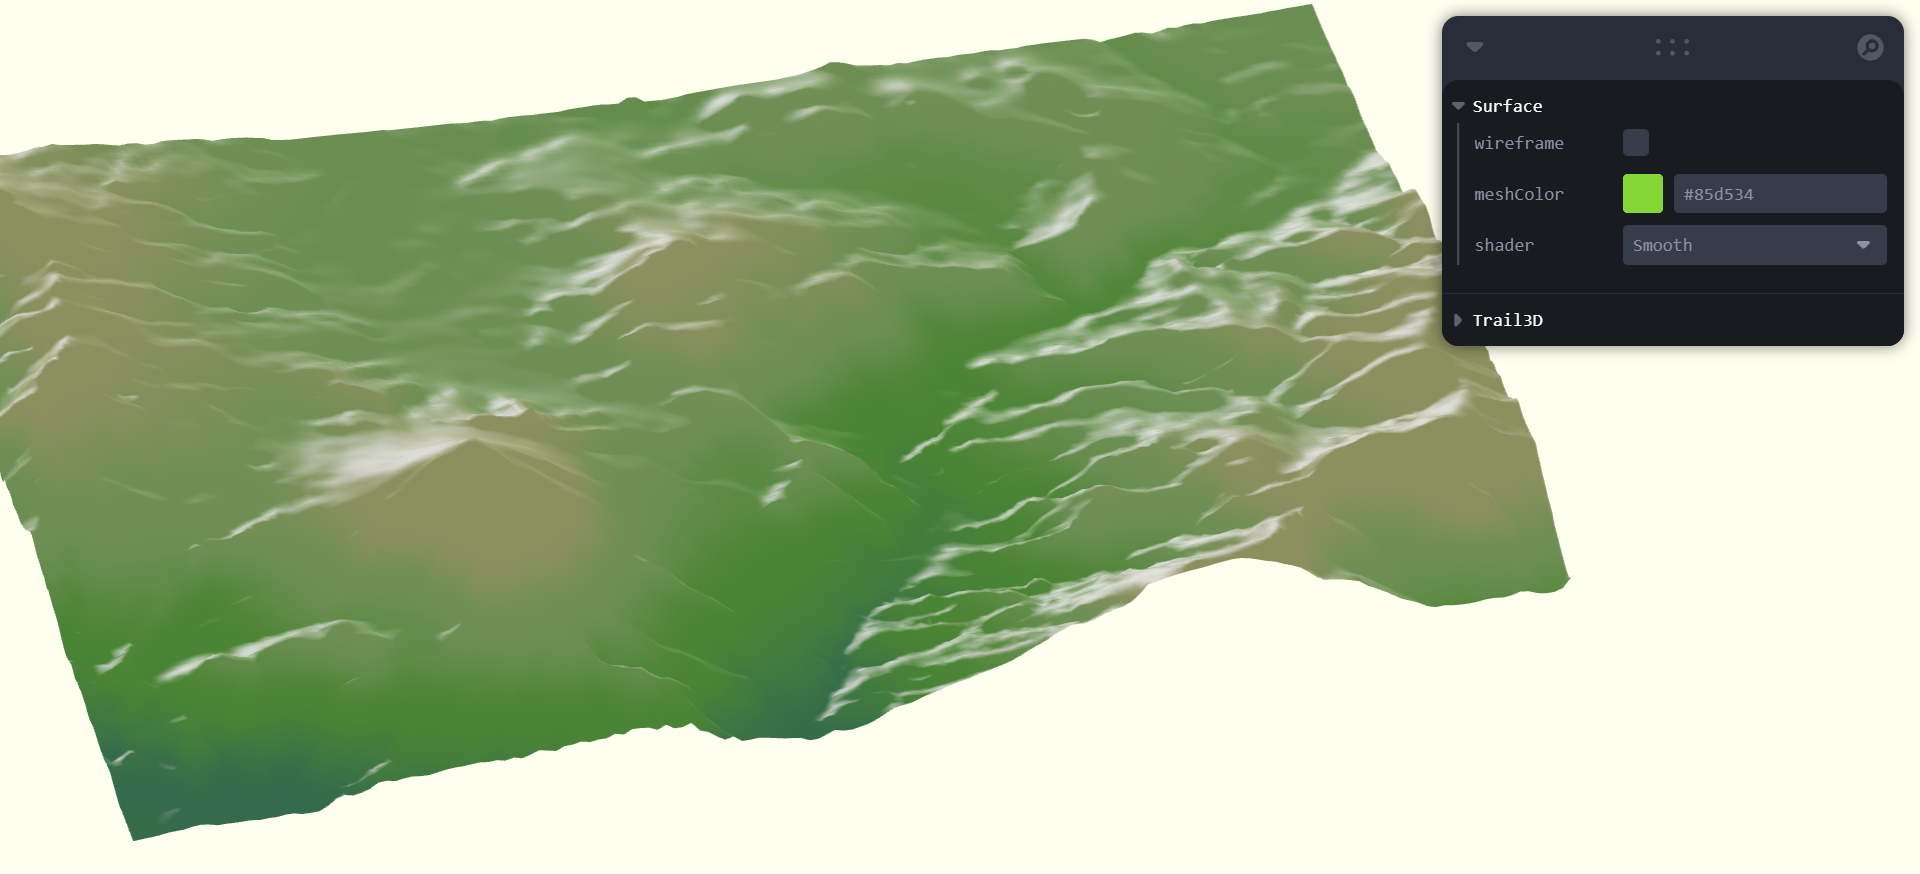
Click and hold the left mouse button to rotate the view, pan using Ctrl+Drag, or use the scroll wheel/pinch gesture to zoom into your desired area of the DTM.
Define Start & End Points
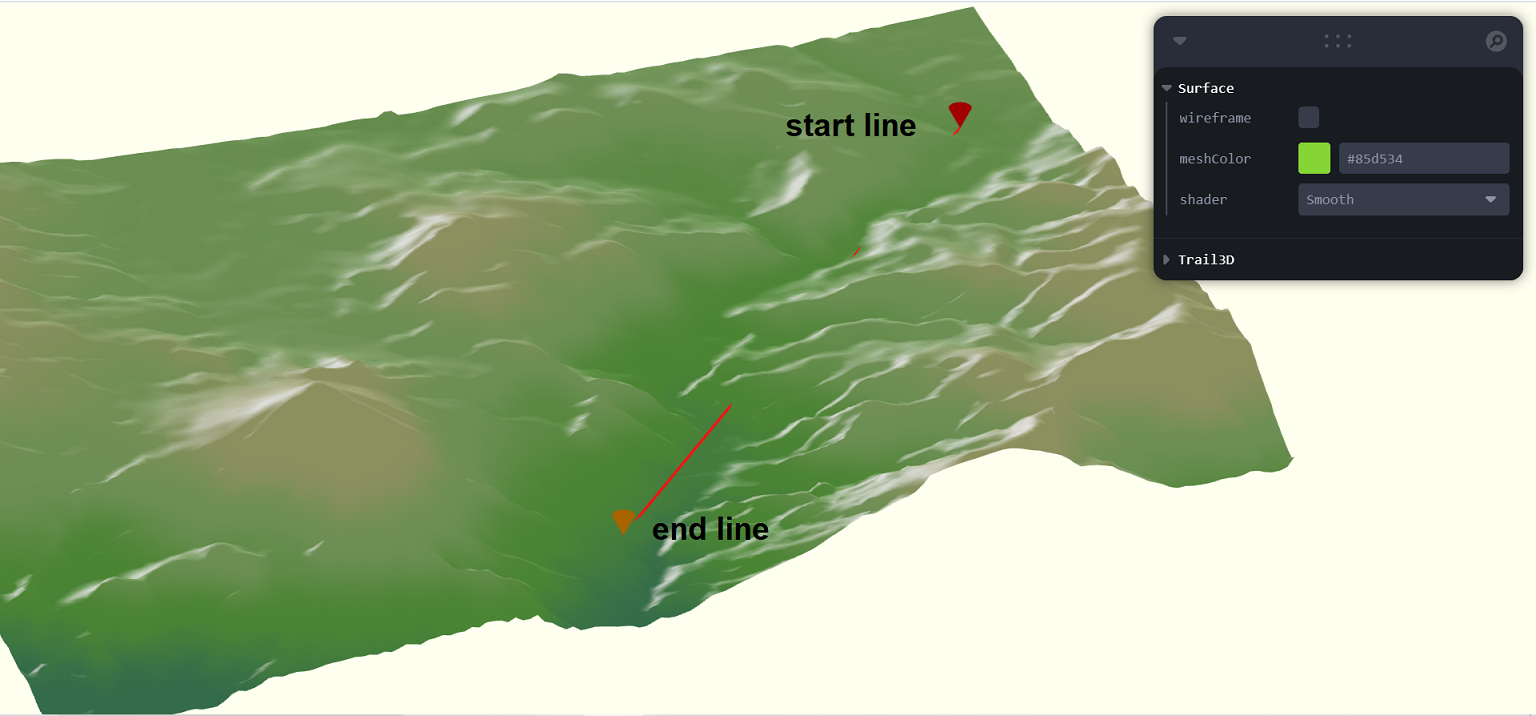
Click once at the desired starting point, and click again at the intended endpoint for your path. Press Escape (ESC) key to cancel line painting.
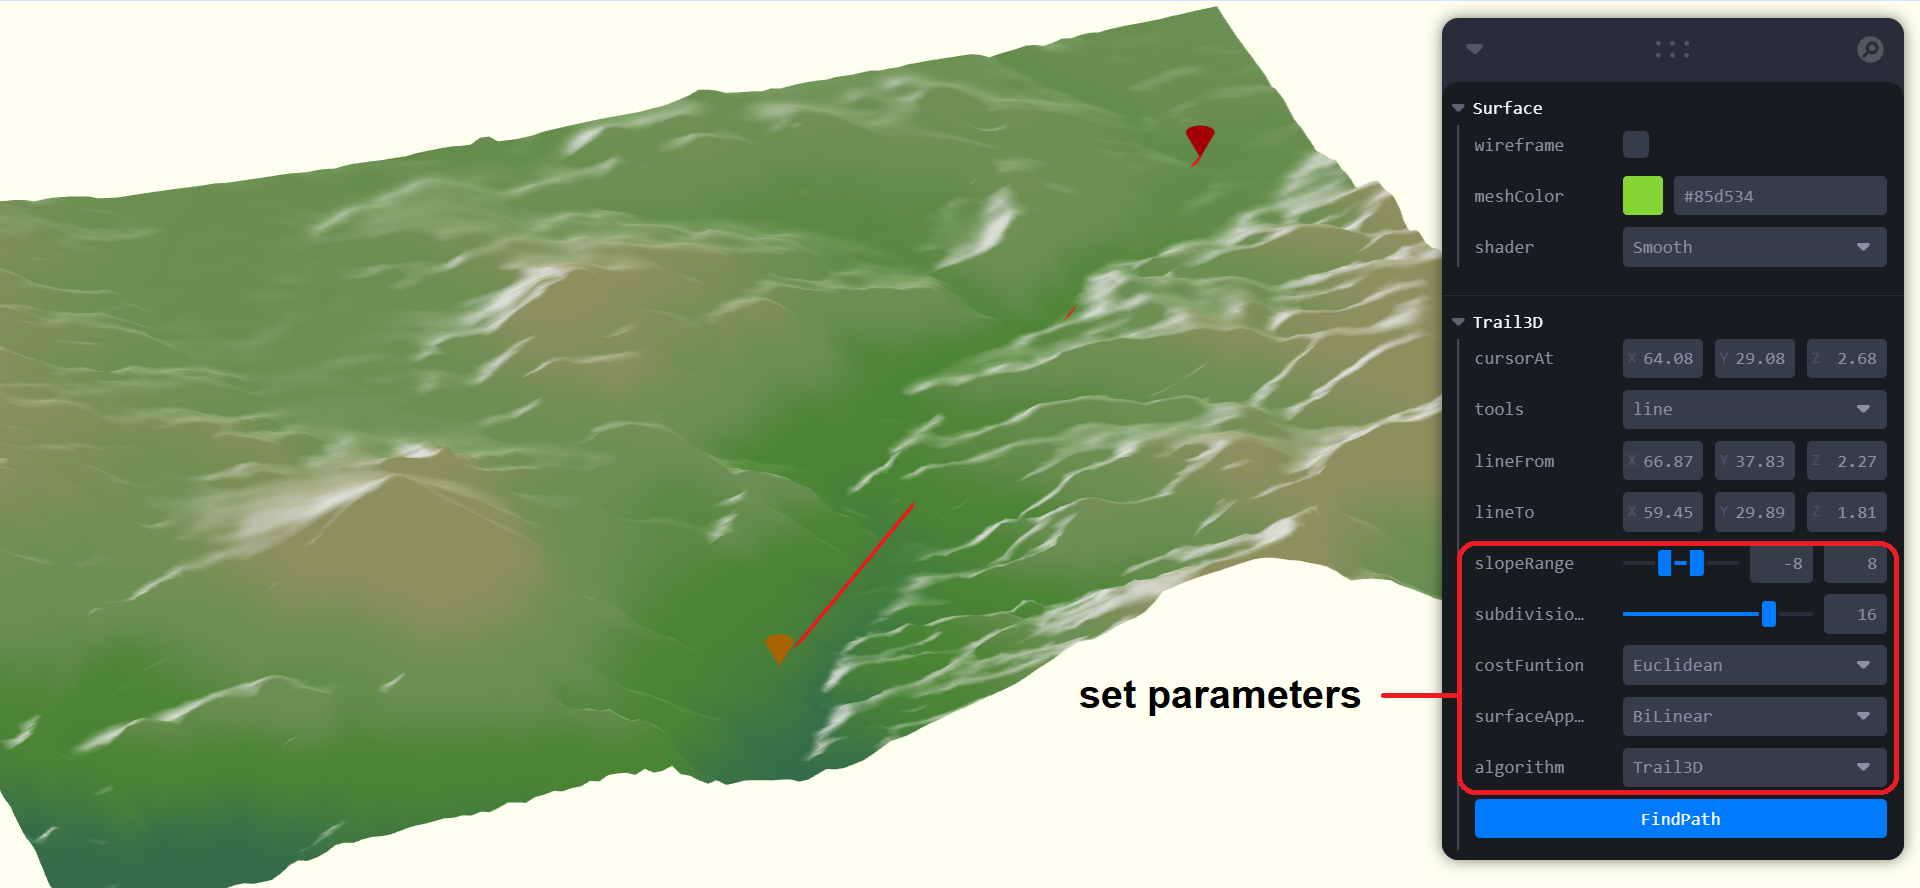
Input Parameters
- Slope Range: Specify the minimum and maximum permissible slope (as a percentage) for physical viability.
- Subdivisions: Determine the necessary number of surface element subdivisions required.
- Cost Function & Approximation: Select your desired cost model (e.g., Euclidean, Manhattan) and surface approximation method (Bilinear, Lagrange).
- Algorithm Selection: Choose the pathfinding algorithm required for the simulation.
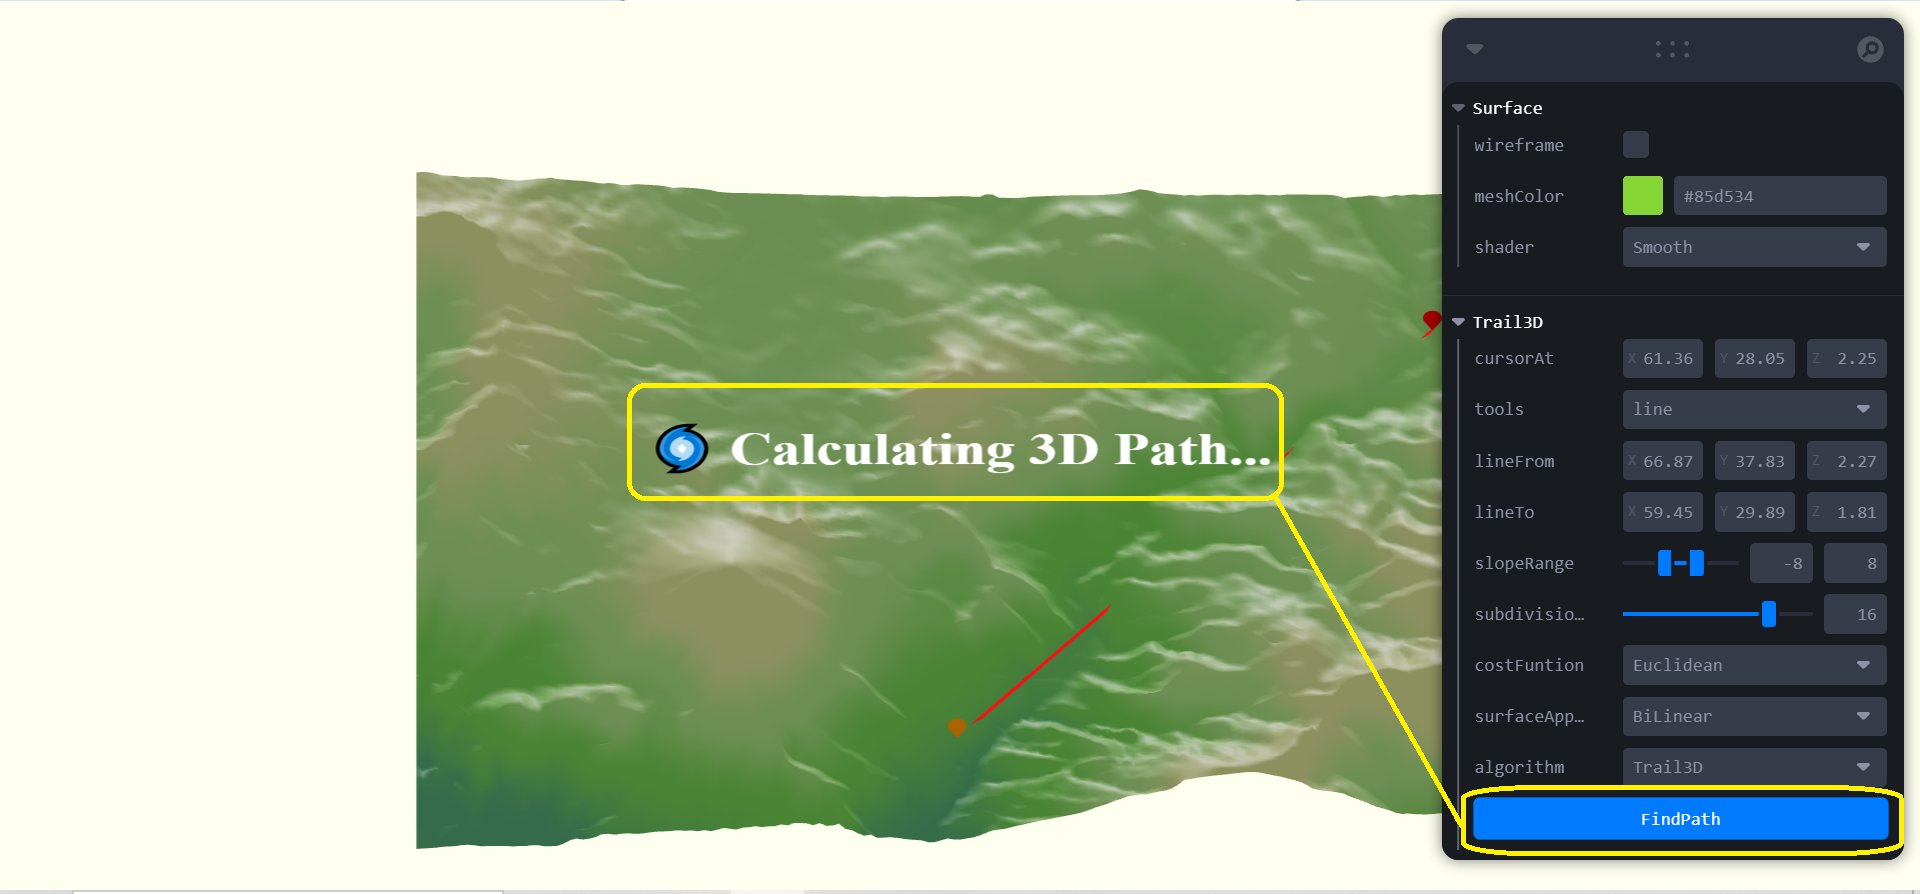
- Calculate Path: Click the
FindPathbutton to run and display the 3D path.
💡 Advanced Tips & Troubleshooting
A* Algorithm Note
When selecting the A* algorithm, please note that subdivisions will be set to "1".
Context Menu Actions
Right-click anywhere along the generated 3D path line to access a submenu of advanced options.
Beyond A*: Deterministic Pathfinding in Variable 3D Space.
Trail3D: Solving the Hard Problem of Surface Navigation.
The Limitation of Standard Algorithms
Using standard pathfinding algorithms, may not always be the best choice for scenarios constrained by real-world physics, such as steep slopes or irregular surfaces. They treat the world as nodes, not continuous surfaces.
Trail3D is a robust, A* graph traversal variant that elevates path planning from simple node connection to advanced **surface interpolation**. We calculate highly accurate routes in 3D space, with deterministic and predictable results ideal for complex simulations, robotics integration, and reliable system design.
Deterministic & Predictable
CORE ADVANTAGE
- Adherence to physical laws.
- Ideal for high-stakes industrial automation.
- Minimizes operational risk and deviation.
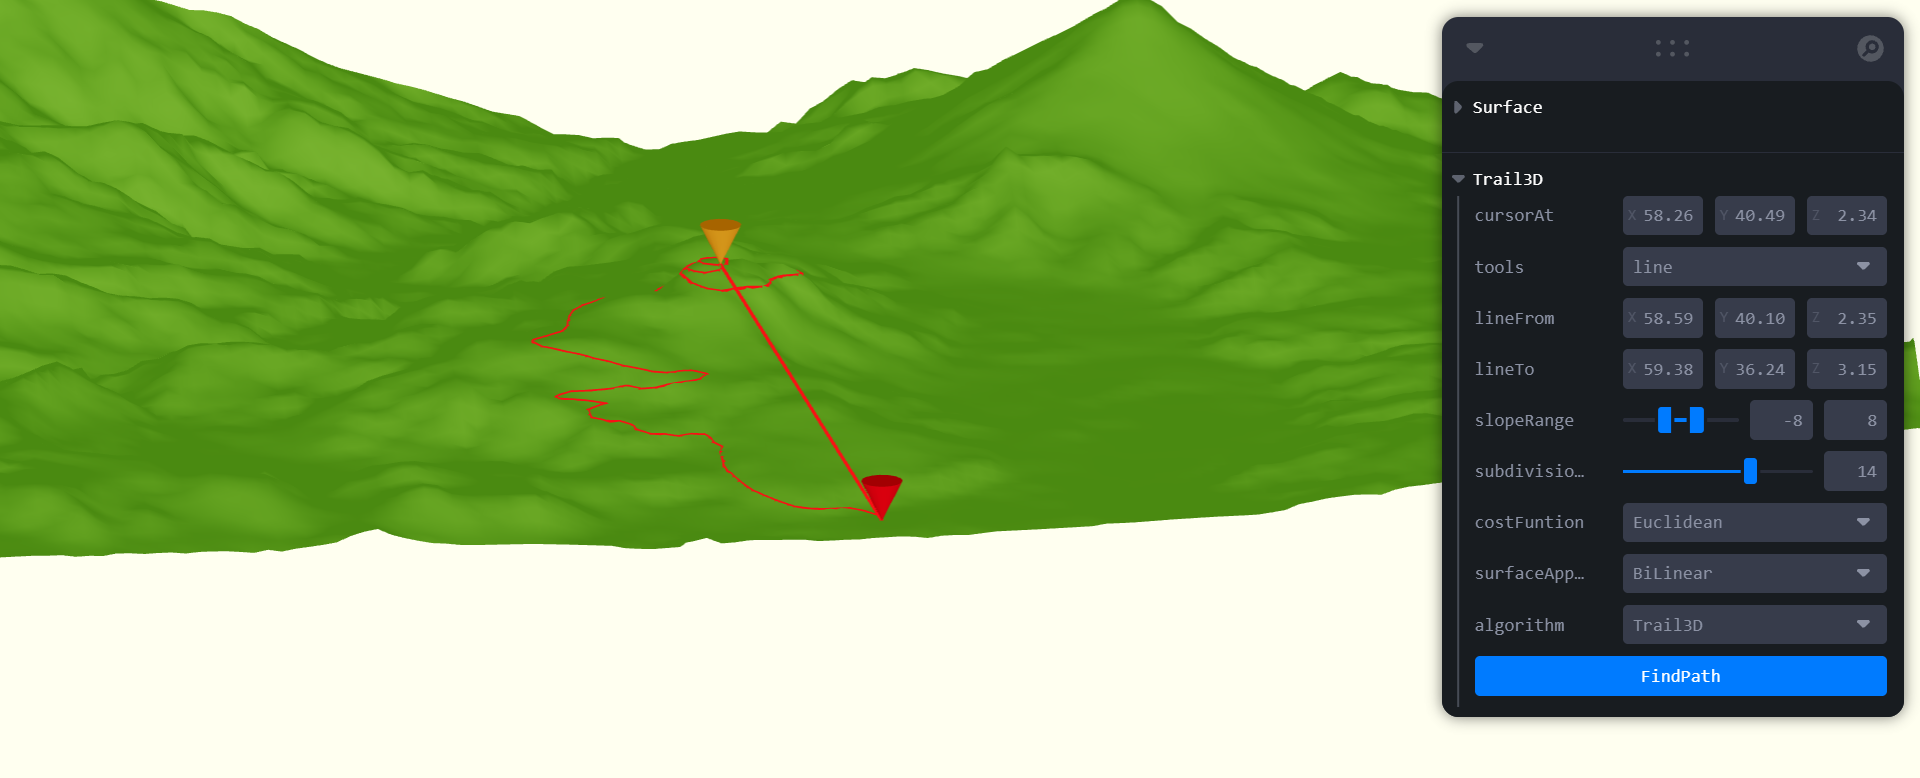
Optimizing Robotic Routing in Complex Terrain.
Trail3D: Deterministic 3D Pathfinding Engineered for Precision.
Don't just find a path—find the most viable one.
Trail3D is an advanced, deterministic algorithm designed to calculate precise optimal routes (Point A to Point B) across complex surfaces and digital terrain models (DTMs). By rigorously factoring in slope constraints, elevation changes, and physical limitations, we provide engineered paths for outdoor robotics, ensuring a viable solution.
Output: Optimized 3D Path.
Engineered for Precision
Our paths are designed not just to connect two points, but to maintain engineering standards throughout the entire route.
Knowledge Base
Frequently Asked Questions